LingBot-VLA
Contents
TL;DR
Model Architecture
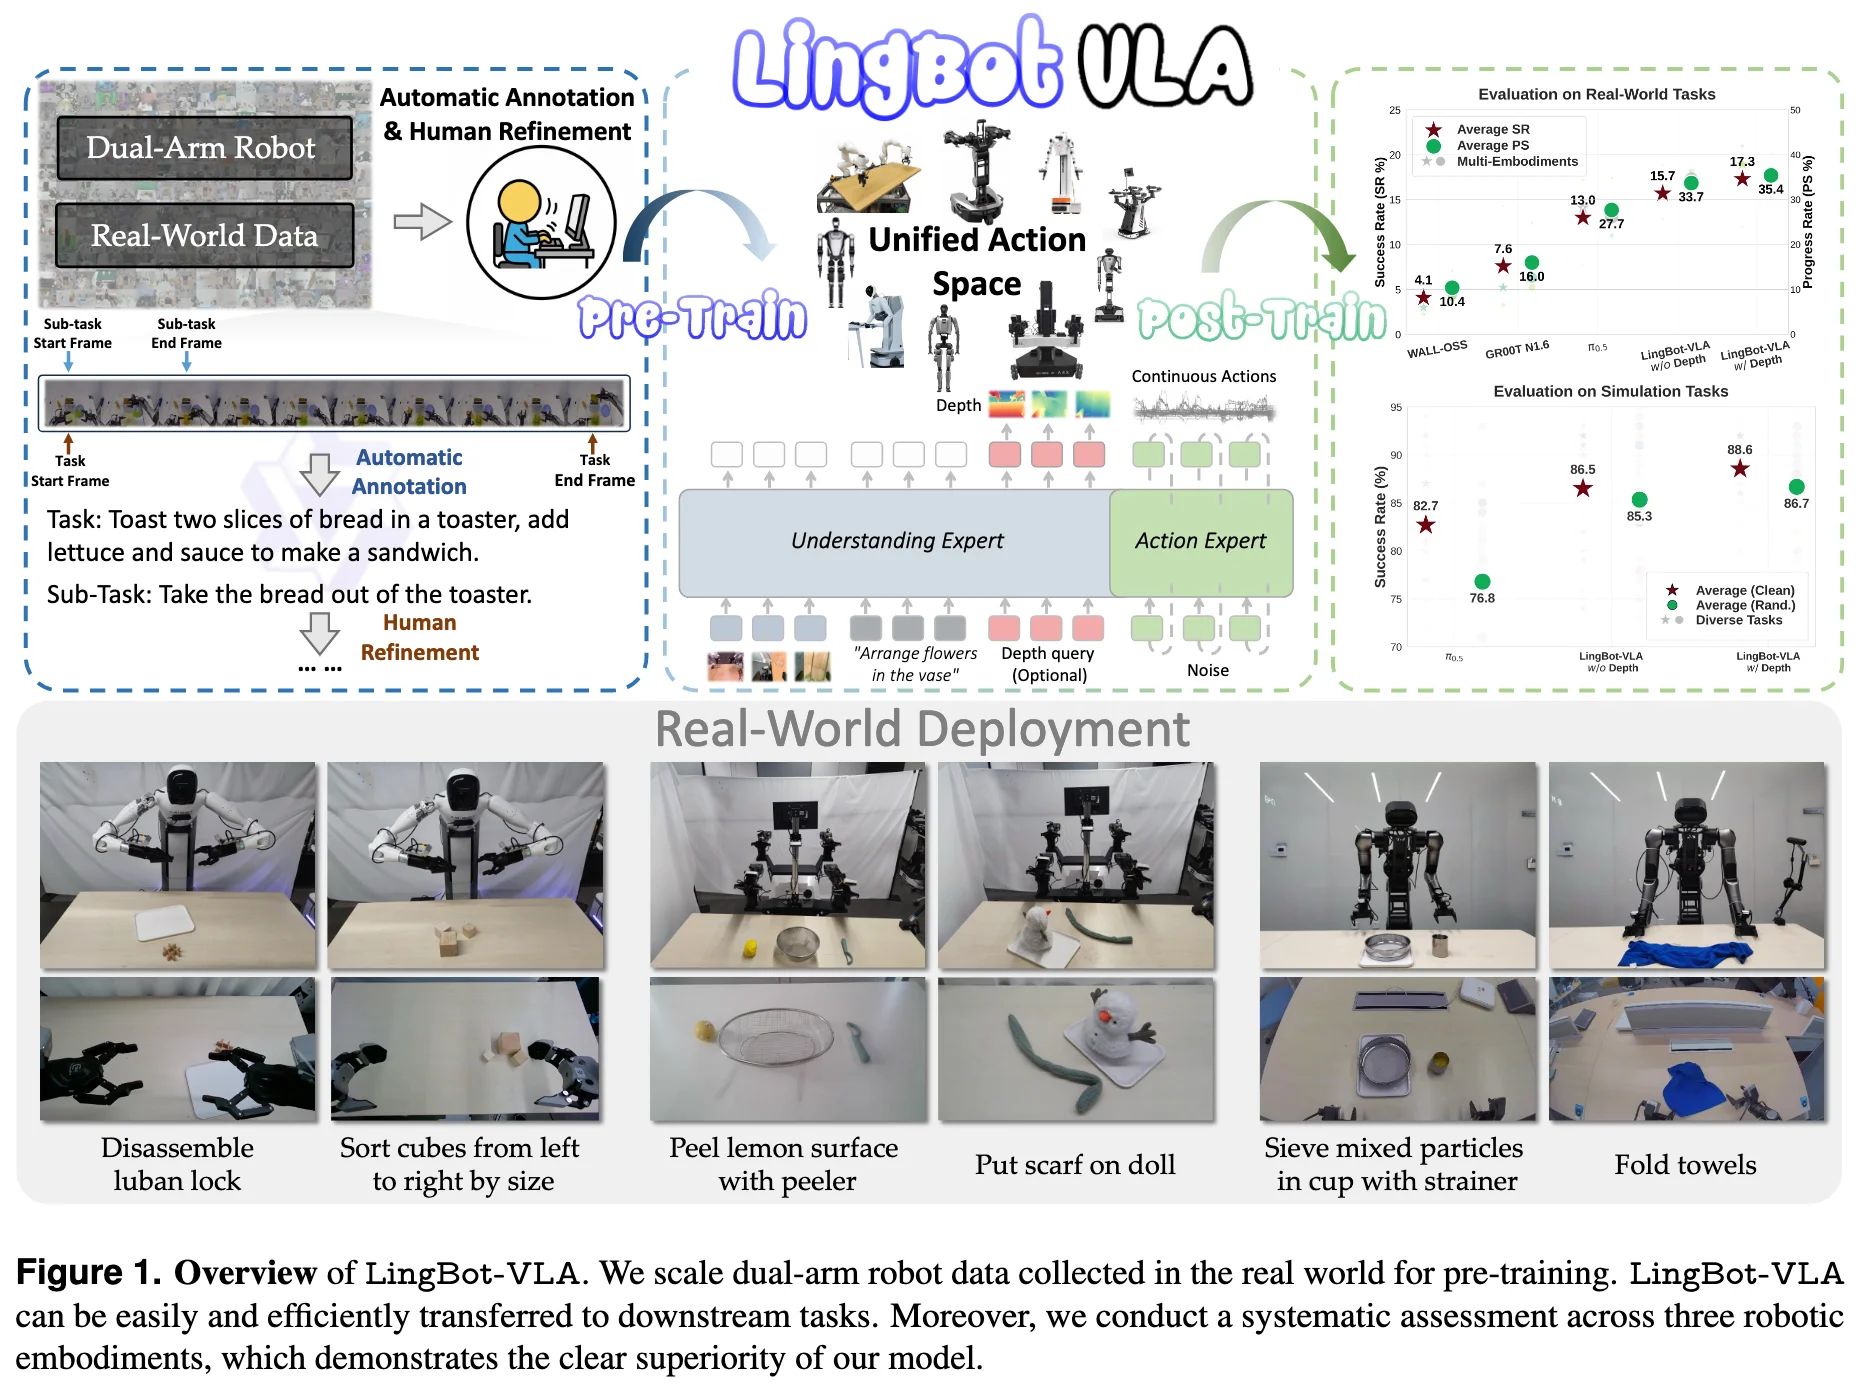
Data Recipe
Data Collection
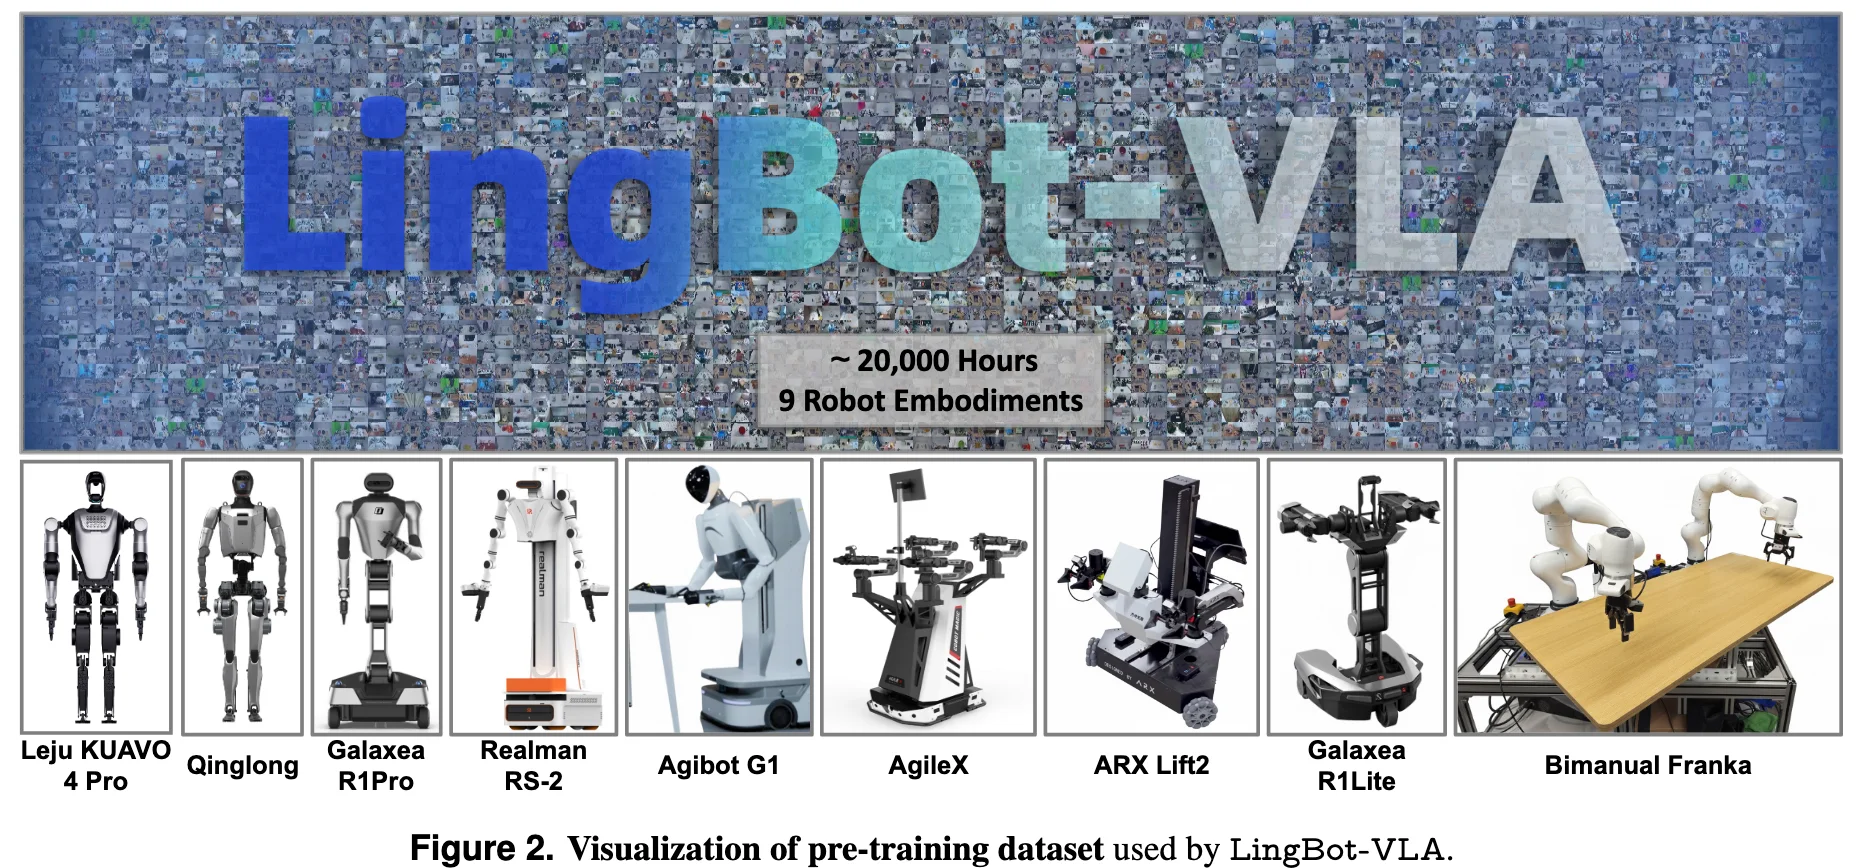
- teleoperated data collected from 9 popular dual-arm robot embodiments with grippers as end-effectors.
Data Filtering
Automated Filtering
static frames at the start and end of the videos are eliminated at this stage.
Manual Review
Data Labeling
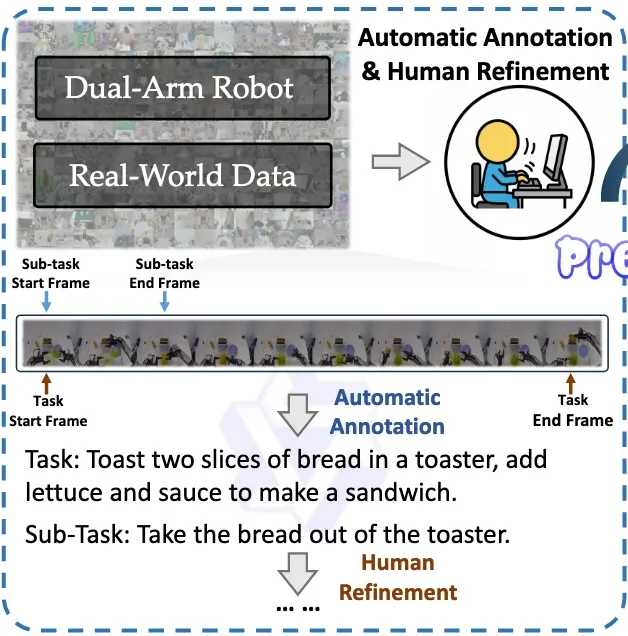
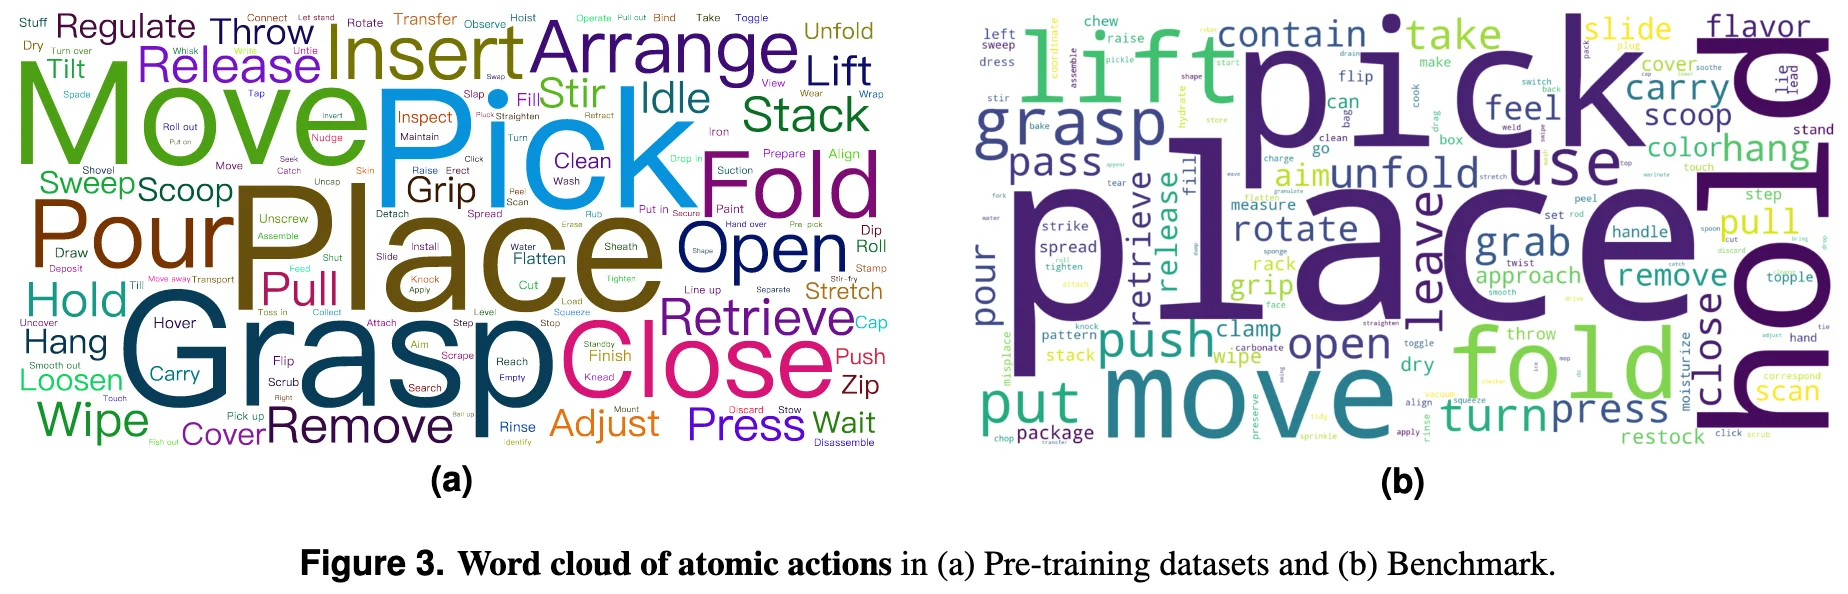
- Video Segment: Decomposed into clips by human annotators according to predefined atomic actions.
- Instruction Annotation: Employ Qwen3-VL-235B-A22B for precise annotation of task and sub-task instructions.