Robo2VLM
Contents
arXiv

TL;DR
Motivations & Innovations
Data Recipe
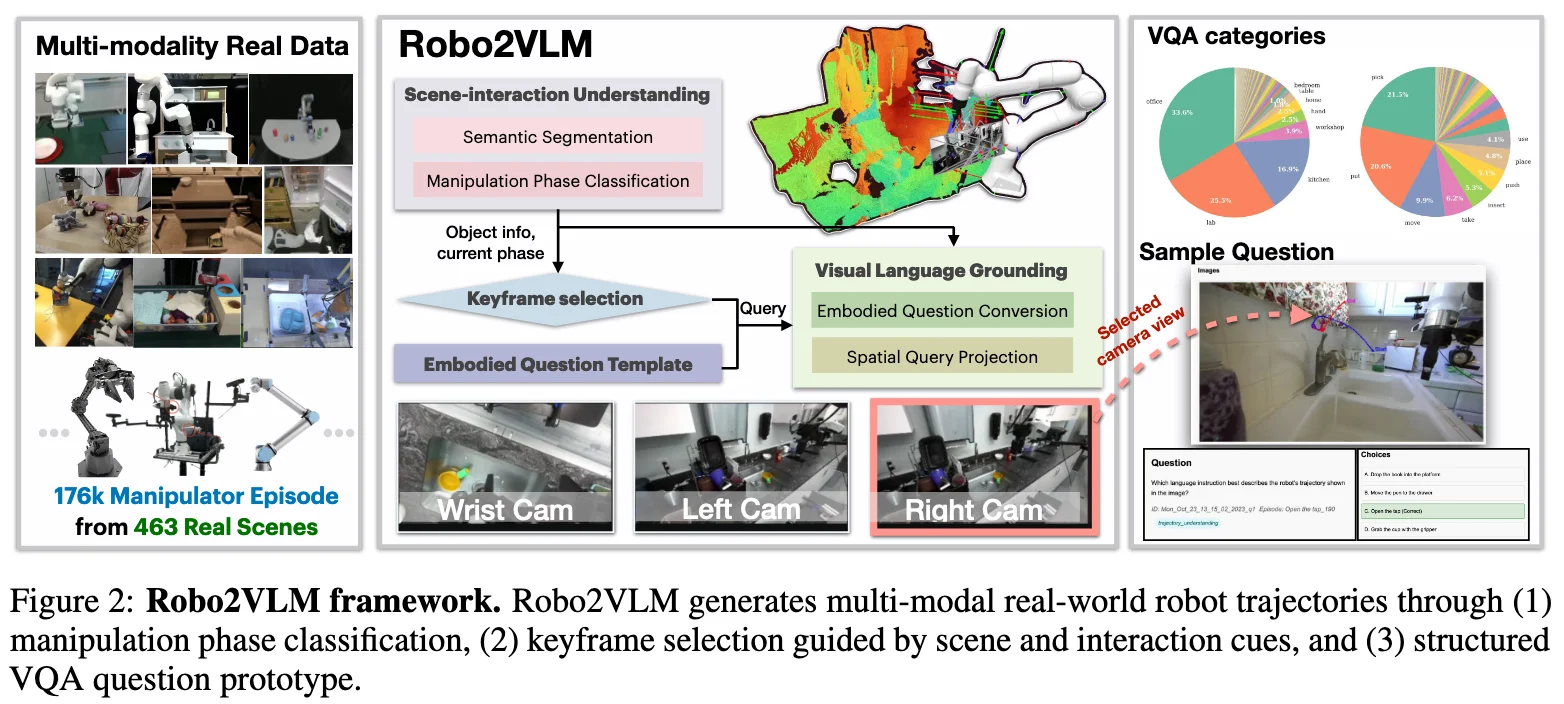
Scene-Interaction Understanding
Embodied Scene Understanding:
Input:
- a task description in nature language
- images from different camera views
Output:
- using an off-the-shelf LLM such as Qwen 2.5 to obtain target object, scene, task and skill description.
Manipulation Phase Segmentation:
Input:
- 12
Output:
- 12