galaxea-open-world-dataset
Contents
arXiv

https://huggingface.co/datasets/OpenGalaxea/Galaxea-Open-World-Dataset
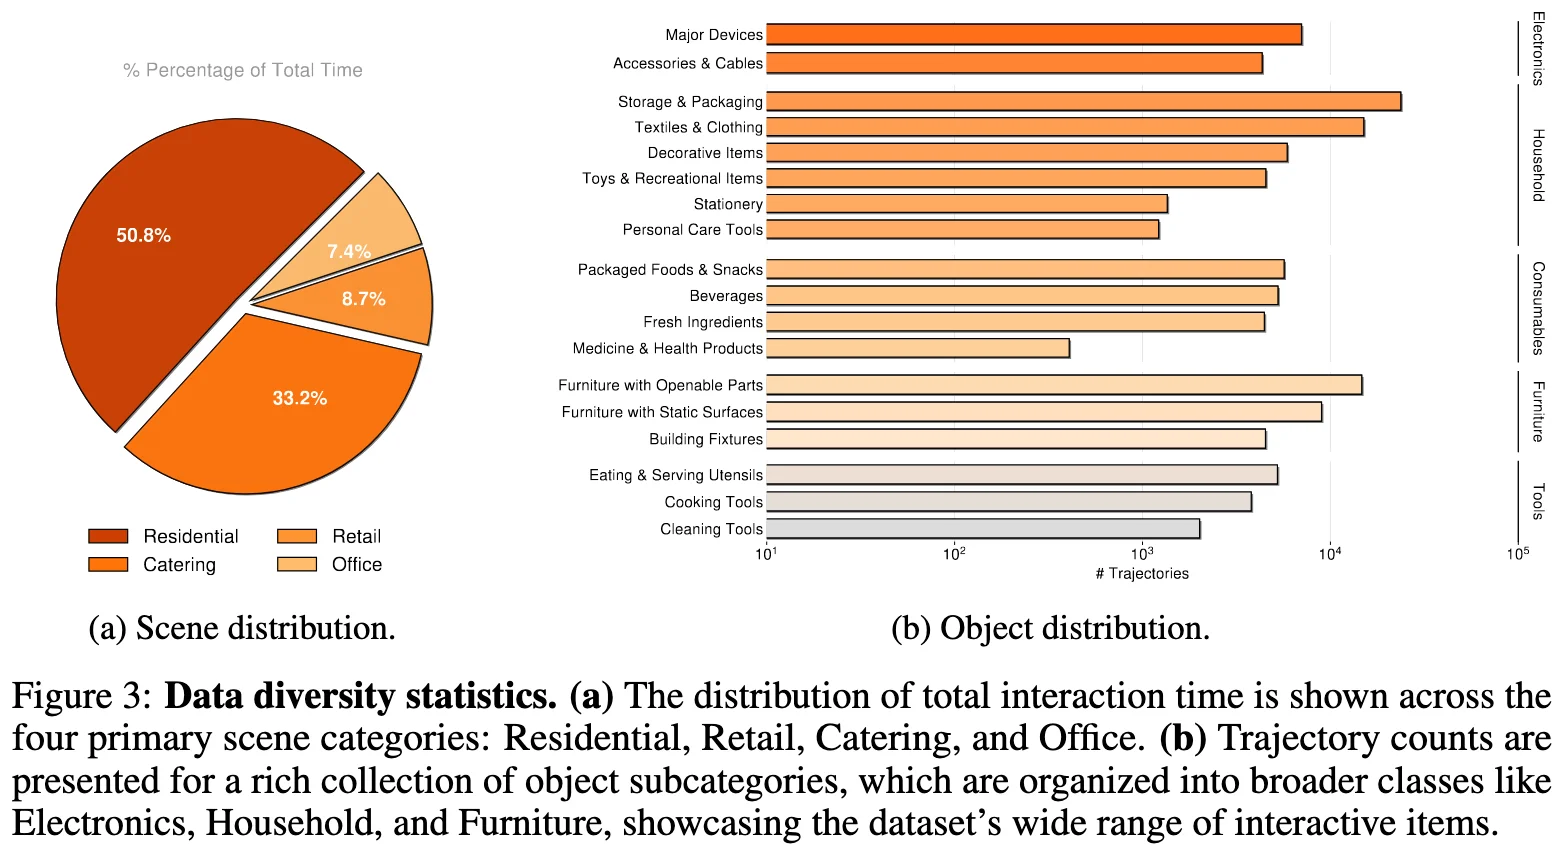
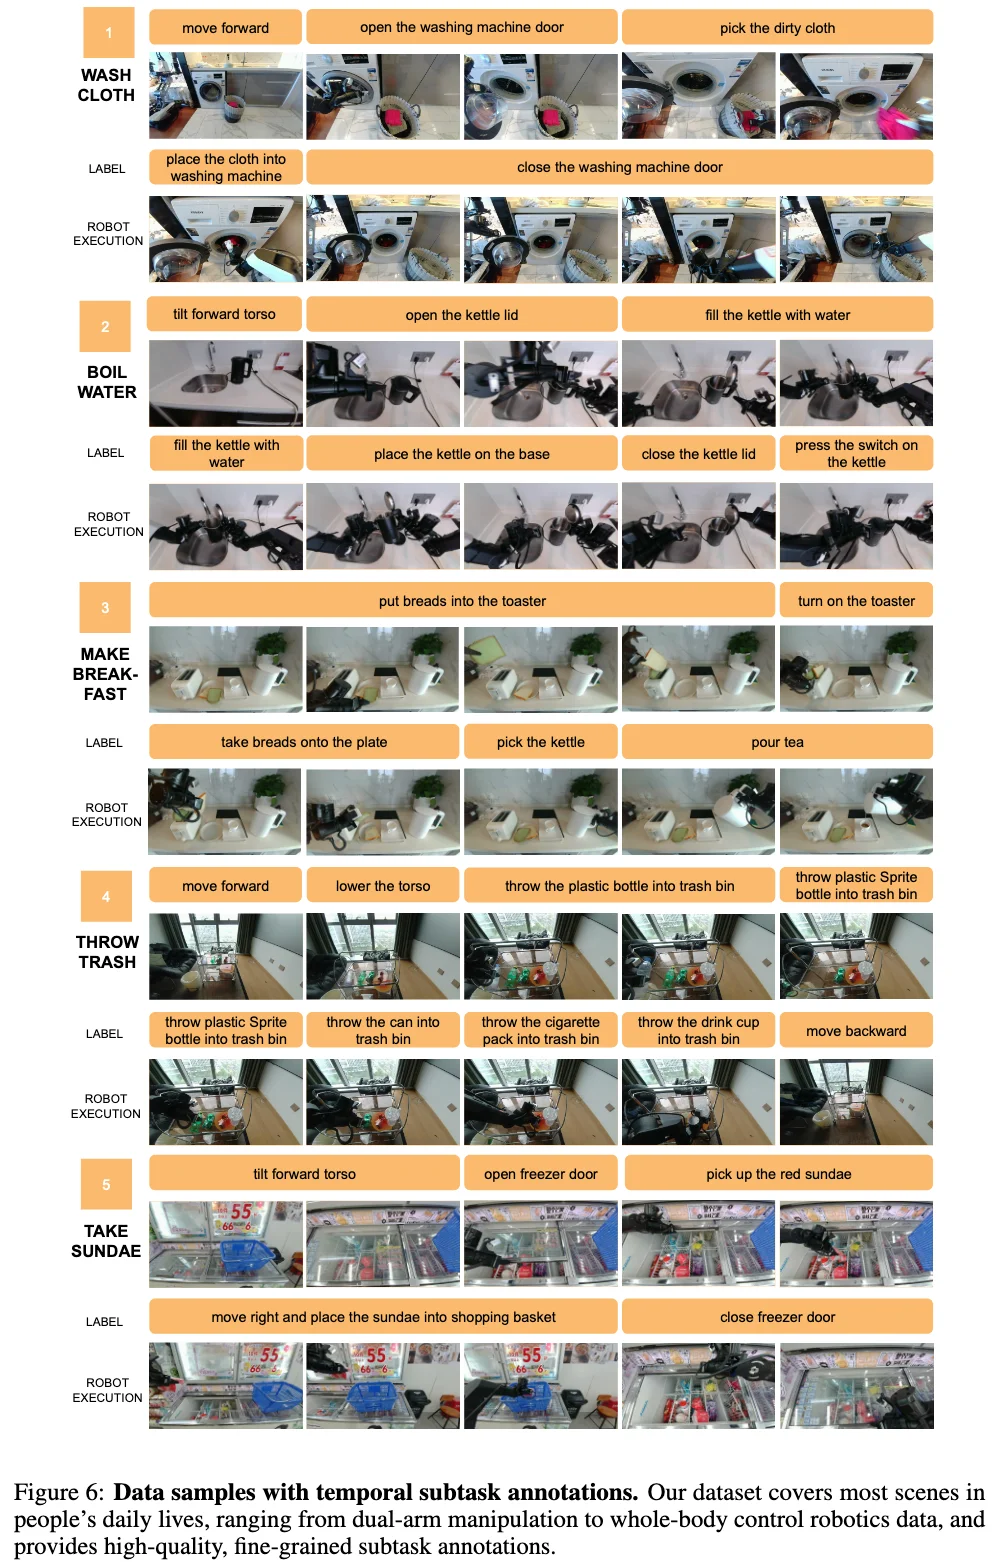
500+ hours of real-world mobile manipulation data. All data collected using one uniform robotic embodiment for consistency. Fine-grained subtask language annotations. Covers residential, kitchen, retail, and office settings. Dataset in RLDS and LeRobot format.
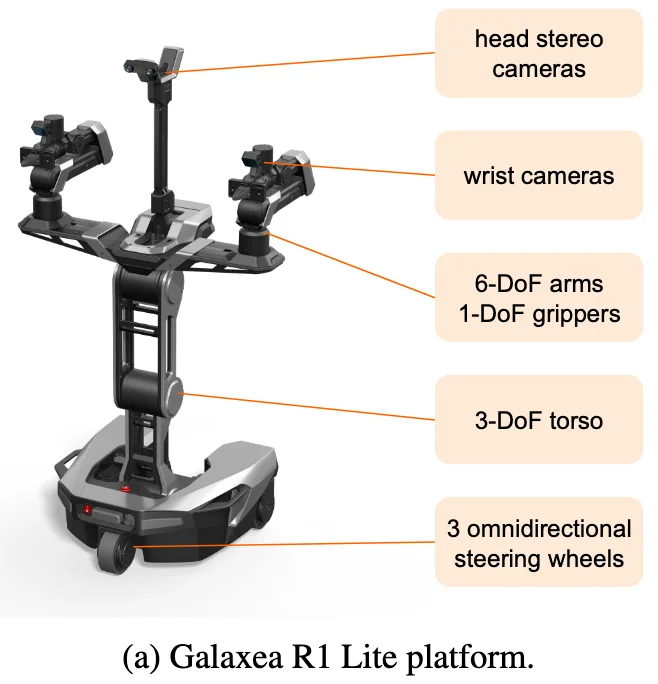
| 机器人本体 | 全身参数 | 手臂 | 末端执行器 | 躯干参数 | 底盘参数 | 传感器 | 算力参数 |
|---|---|---|---|---|---|---|---|
全向轮式移动双臂机器人,躯干可升降 | 总高1280 mm 底盘宽600 mm 平台宽670 mm 全身自由度23 | 双臂6-DoF x2 臂长600 mm 负载额定 3 kg,最大 5 kg 安装上装 | 类型平行夹爪 腕部球形腕 | 自由度3 工作空间0–1.7 m | 自由度6 移动速度1.5 m/s | headstereo RGB ×1 wristRGB-D ×2(选配) | CPUi9-12900HK,14 核,2.5 GHz 内存32 GB RAM 存储1 TB SSD |
Table 1. Galaxea Open-World dataset scale. (identical embodiment, isomorphic teleoperation)
| trajectories | task categories | scenes (real-world) | unique objects | skills |
|---|---|---|---|---|
~100K | 150 | 50 | 1600+ | 58 operational skills fine-grained pick-and-place → coordinated whole-body manipulation |