3DAL: Offboard 3D Object Detection from Point Cloud Sequences
Contents
Waymo LLC arXiv 2103.13612
TL;DR
Motivations & Innovations
Approach
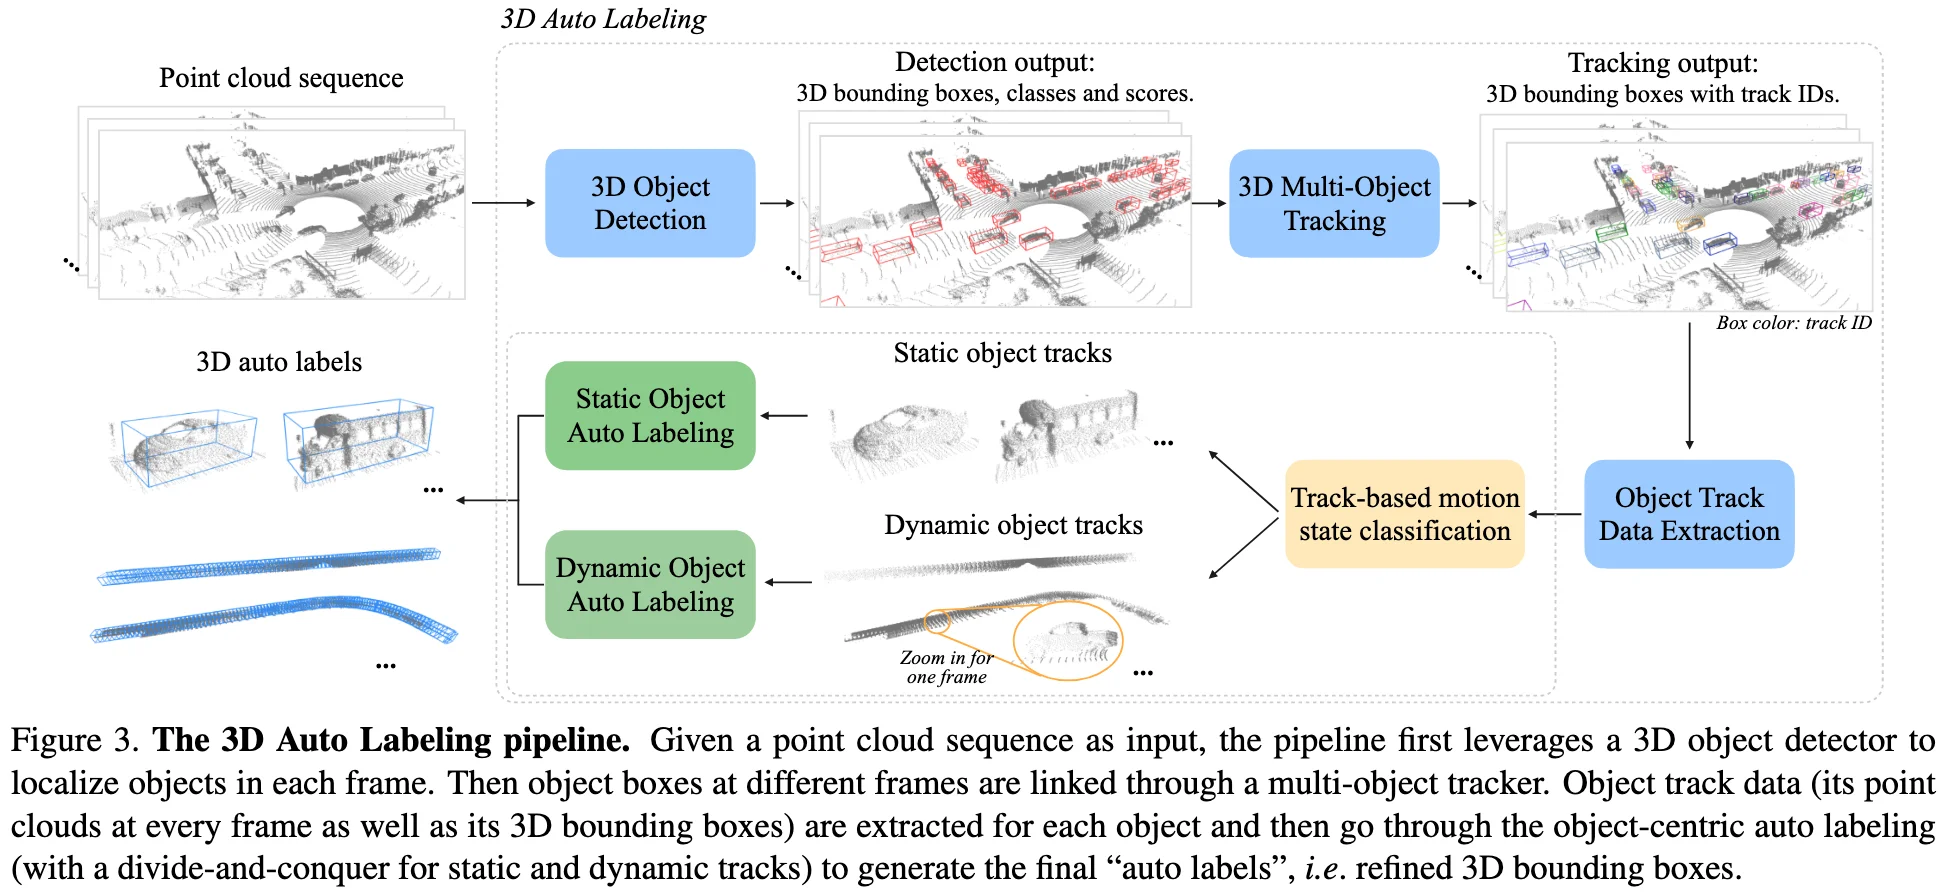
Multi-frame 3D Object Detection
Multi-object Tracking
tracking-by-detection: using detector boxes for associations and Kalman filter for state updates.
Object Track Data Extraction
Object-centric Auto Labeling
Divide and conquer: motion state estimation
A linear classifier using a few heuristic features from the object track’s boxes can already achieve 99%+ motion state classification accuracy for vehicles.
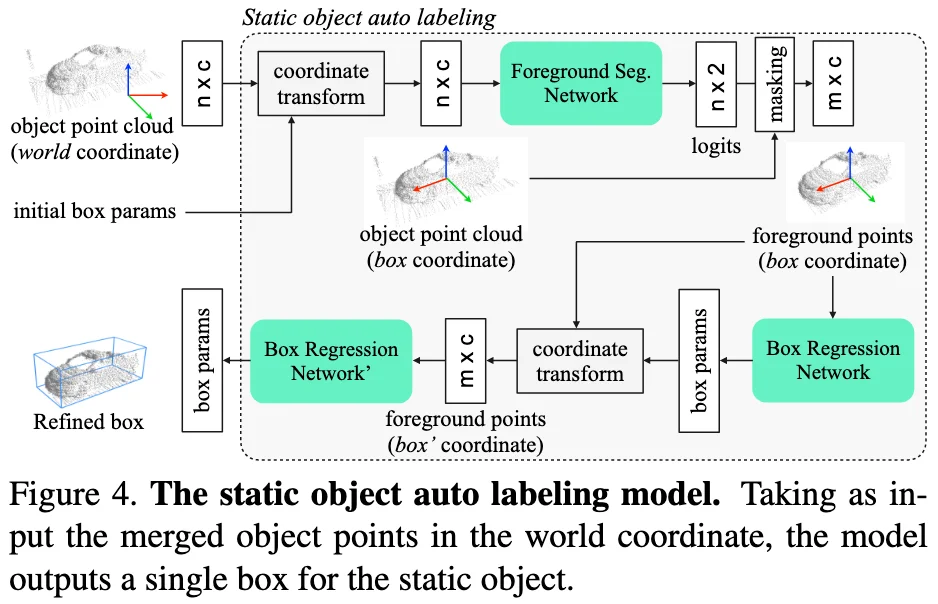
Static object auto labeling
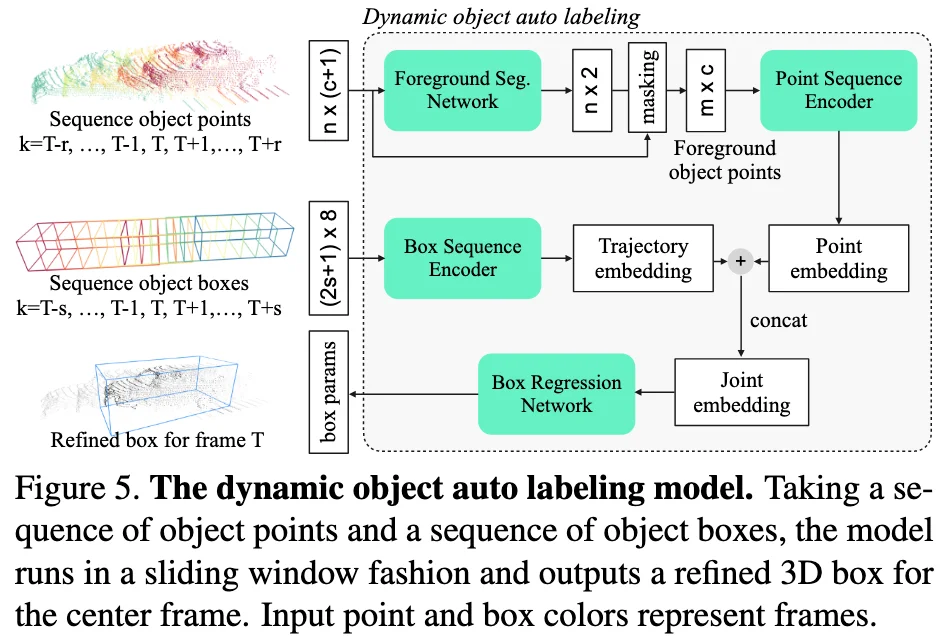
Dynamic object auto labeling